
巡检机器人
一、方向简介
巡检机器人研究面向园区、厂区、地下管廊、电力设施、交通枢纽、仓储物流及危险作业区域等场景,重点解决复杂环境下机器人的自主巡检与智能运维问题。该方向围绕环境感知、目标识别、自主定位、路径规划、运动控制、多传感器融合与异常检测等关键技术展开,提升机器人对设备状态、环境变化和潜在风险的实时发现能力。研究内容包括基于视觉与激光雷达的地图构建、复杂环境导航避障、设备表计识别、热异常检测、语音交互及远程协同控制等。通过将机器人技术与人工智能、边缘计算和智能运维平台深度融合,可实现巡检流程自动化、风险识别智能化和管理决策数据化,降低人工巡检成本与安全风险,提高重点场所和关键设施的运行保障能力。
I.Introduction to the Direction
Inspection robot research focuses on scenarios such as industrial parks, factory areas, underground utility tunnels, power facilities, transportation hubs, warehousing and logistics, and hazardous operation areas, with an emphasis on addressing autonomous inspection and intelligent operation and maintenance of robots in complex environments. This direction focuses on key technologies including environmental perception, target recognition, autonomous localization, path planning, motion control, multi-sensor fusion, and anomaly detection, improving robots’ real-time ability to identify equipment status, environmental changes, and potential risks. Research content includes map construction based on vision and LiDAR, navigation and obstacle avoidance in complex environments, equipment meter recognition, thermal anomaly detection, voice interaction, and remote collaborative control. By deeply integrating robotic technologies with artificial intelligence, edge computing, and intelligent operation and maintenance platforms, inspection processes can be automated, risk identification can be made intelligent, and management decisions can be data-driven, reducing the cost and safety risks of manual inspections and improving operational support capabilities for key sites and critical facilities.
二、研究内容与成果
智能巡检机器狗平台与自主感知技术
课题组开展了面向复杂场景的智能巡检机器狗平台研究,围绕移动机器狗本体、多源感知融合、边缘智能计算与远程协同控制等方面持续攻关,构建了具备环境感知、自主导航、状态识别与任务执行能力的巡检机器狗系统。
II.Research Content and Achievements
Intelligent Inspection Robot Dog Platform and Autonomous Perception Technologies
The research group has conducted research on intelligent inspection robot dog platforms for complex scenarios, focusing on continuous advances in mobile robot dog platforms, multi-source sensing fusion, edge intelligent computing, and remote collaborative control. An inspection robot dog system with capabilities in environmental perception, autonomous navigation, status recognition, and task execution has been developed.
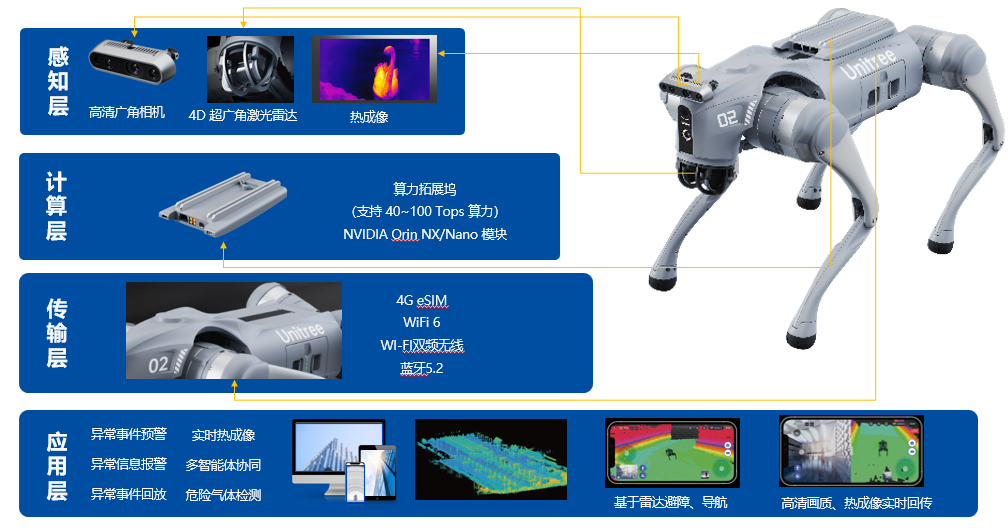
巡检机器狗架构图
Inspection Robot Dog Architecture Diagram
在感知层面,形成了融合视觉、激光、热成像等多模态信息的环境理解技术,可满足复杂环境下目标识别、状态监测与异常发现需求。在系统层面,研究了机器人端智能计算与云边协同架构,实现巡检数据实时处理、远程交互和任务管理。相关成果提升了巡检机器人的环境适应能力、运行稳定性与智能化水平,为多行业场景应用奠定了基础。
At the perception level, multimodal environmental understanding technologies integrating visual, LiDAR, thermal imaging, and other information have been developed to meet the needs for target recognition, status monitoring, and anomaly detection in complex environments. At the system level, research has been conducted on intelligent computing on the robot side and cloud-edge collaborative architectures, enabling real-time inspection data processing, remote interaction, and task management. These achievements have improved the environmental adaptability, operational stability, and intelligence level of inspection robots, laying a foundation for applications across multiple industry scenarios.
面向电力场景的数字孪生智能巡检系统
课题组面向大范围、复杂环境巡检需求,开展多智能体巡检系统研究,重点突破多机器人协同感知、任务分配、路径规划、集群控制与协作决策等关键技术,构建了空地协同、异构协同的智能巡检体系。
Digital Twin Intelligent Inspection System for Power Scenarios
The research group has conducted research on multi-agent inspection systems to address the needs of large-scale inspection in complex environments, focusing on key technologies including multi-robot collaborative perception, task allocation, path planning, swarm control, and collaborative decision-making, and has developed an intelligent inspection system featuring air-ground collaboration and heterogeneous collaboration.
通过融合地面机器人、无人机及固定感知节点等多类智能体,系统可实现大场景快速覆盖、重点区域精细巡检以及异常事件协同处置,提升巡检效率与任务执行灵活性。围绕动态环境下的信息共享与协同决策问题,课题组形成了多智能体自主协作与群体智能相关研究成果。
By integrating multiple types of agents, including ground robots, unmanned aerial vehicles, and fixed sensing nodes, the system can achieve rapid coverage of large-scale environments, detailed inspection of key areas, and coordinated handling of abnormal events, improving inspection efficiency and flexibility in task execution. Focusing on information sharing and collaborative decision-making in dynamic environments, the research group has developed research achievements related to multi-agent autonomous collaboration and swarm intelligence.
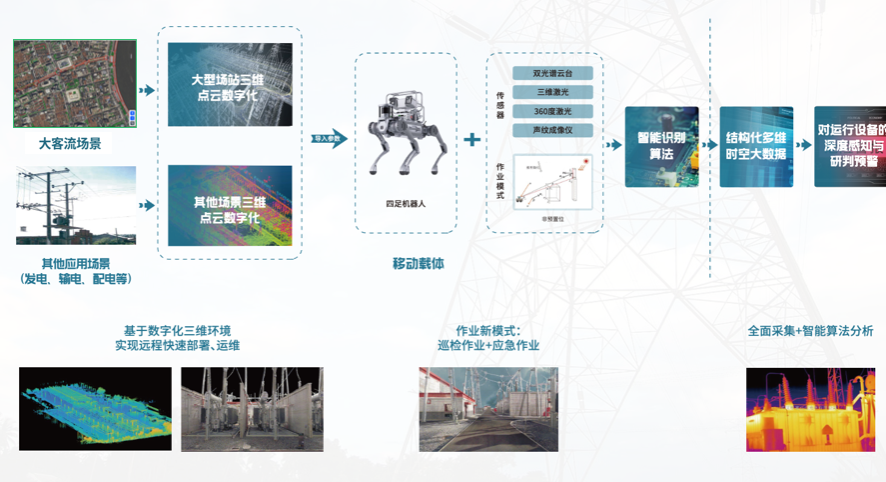
多智能体巡检流程
Multi-Agent Inspection Process